Pelvis Marker Transformation
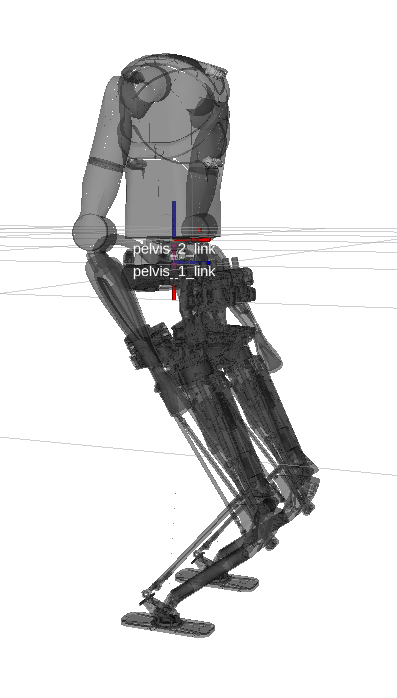
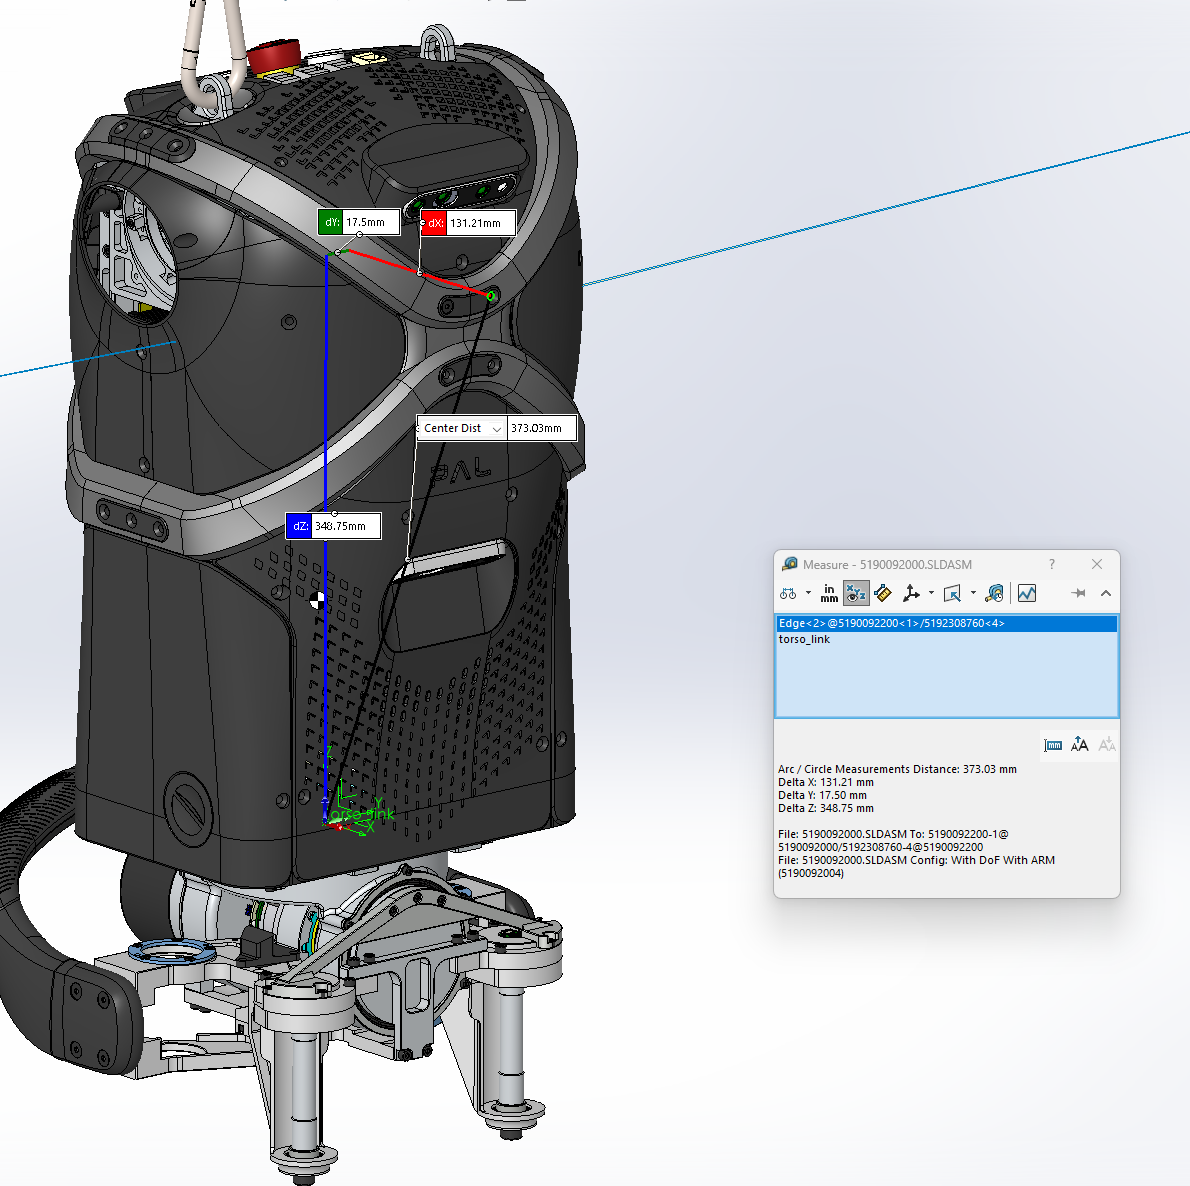
Transformation from the OptiTrack pelvis marker to an upper-body reference thread.
Define the static tf to know where the "reference screw" is on the robot:
rosrun tf2_ros static_transform_publisher 0.13121 0.0175 0.34875 0 0 0 torso_link reference_screw
rosrun tf2_ros static_transform_publisher 0.018341 0.018591 -0.023462 0 0 0 reference_screw reference_marker
About torso_link->reference_screw transform
The shown transformation defines the spatial relationship between the OptiTrack rigid body frame pelvis_2_link and a mechanical reference thread located in the upper body of the Kangaroo robot.
This transformation can be used as an initial starting transformation to integrate the Kangaroo robot into the OptiTrack coordinate system. It serves as a reasonable initial guess for subsequent refinement or calibration steps (e.g. hand–eye calibration or optimization-based alignment).